Wow, I just saw this simple little project a guy built, and I thought it would be pretty simple to make with a NXT, a sound sensor and a motor. Set the motor to position the mouth open or closed based on the intensity of the sound. Pretty neat.
If anyone does this, I would love to show it off, so let me know.
Update: I have already built one of these. It turned out pretty well. Am working on a video now and I expect to have it in a day or two.
Sunday, November 1, 2009


Friday, October 30, 2009
Friday's Idea
Here’s an idea that I think is pretty cool, a robot that lays bricks. Not Lego bricks, but regular construction bricks.
There have been a few artists and companies that have actually commercialized this and create wonderful works of art. Here is another link to a different company.
Make Magazine recently did an article on some of the mathematics that is required to make some really impressive textures on some walls.

I have tinkered with some of the math, and it is pretty detailed. I hope to get into this project in the future (get in line, buddy). If I do get into this project I would probably use something like dominos or home made wooden bricks to mimic the bricks and I think a gantry style robot will be much easier to construct and program.
There have been a few artists and companies that have actually commercialized this and create wonderful works of art. Here is another link to a different company.
Make Magazine recently did an article on some of the mathematics that is required to make some really impressive textures on some walls.

I have tinkered with some of the math, and it is pretty detailed. I hope to get into this project in the future (get in line, buddy). If I do get into this project I would probably use something like dominos or home made wooden bricks to mimic the bricks and I think a gantry style robot will be much easier to construct and program.
Wednesday, October 28, 2009
Lego in Mainstream Blogs.
Many don’t know that lots of techy blogs often post Lego related posts. What’s nice is they usually don’t post junk, so most of the posts are something that will interest most AFOLs. If you find a big blog that you like, you can usually find all the Lego posts by searching around in the tags. Tags are key words like Lego, Mindstorms, and NXT.
A few of my personal favorites (with links to Lego tags) are Make Magazine, Gizmodo, Boing Boing Gadgets, Wired Magazine, BotJunkie, Engadget, Singularity Hub and Robot Dreams. (Don't forget to come back!)
I would love to know if anyone else has found any good ones.
A few of my personal favorites (with links to Lego tags) are Make Magazine, Gizmodo, Boing Boing Gadgets, Wired Magazine, BotJunkie, Engadget, Singularity Hub and Robot Dreams. (Don't forget to come back!)
I would love to know if anyone else has found any good ones.
Tuesday, October 27, 2009
Early Factory Design Pictures
Here are some very early pics of the Factory so far..
This is the pallet. The pallet is pushed along the conveyor by a lug on the belt. The pallet actually slides on the smooth plates on the side.

The stop is used to position the front of the pallet. A device yet to be developed will push the pallet from the back into the stop. The conveyor will only get the pallet near the station. It will not put the pallet in the final location.
This is the downstream view of a cell. The grey bars on the side are where the pallet will rest. The pallet rides up on them as it enters the cell.

This is the pallet. The pallet is pushed along the conveyor by a lug on the belt. The pallet actually slides on the smooth plates on the side.

The stop is used to position the front of the pallet. A device yet to be developed will push the pallet from the back into the stop. The conveyor will only get the pallet near the station. It will not put the pallet in the final location.

This is the downstream view of a cell. The grey bars on the side are where the pallet will rest. The pallet rides up on them as it enters the cell.

This view is the pallet beginning to ride up onto the cell. 

This is a pallet with a very early version of the car sitting on top. The pallet is in position for assembly work by the robot to begin.

Keep in mind that all designs are completely open to redesign!!

Keep in mind that all designs are completely open to redesign!!
Saturday, October 24, 2009
Robot sympathy
Halloween is great. Lots of horrifying animatronics come out and crazy robot costumes get shown off. Here is a video I enjoyed because for a moment I had sympathy for some wires, nuts and bolts and some wood. It's great because the builder personified the robot simply with eyes, teeth and some strange movements.
Somebody please do something to help!
Somebody please do something to help!
Reality producer lands Lego
I have always wanted a show, a documentary, a series or something on TV about Lego. Looks like it is going to happen. www.variety.com has an article (Reality producer lands Lego) that states that there is something in the works
Five bucks says that Mindstorms won't get much air time. Just a hunch.
Five bucks says that Mindstorms won't get much air time. Just a hunch.
Friday, October 23, 2009
Fridays Idea
This is what I would build if I had 200 NXT sets and about 5000 hours of spare programming time.
Thursday, October 22, 2009
My Factory-The Plan
I wish I could say that I have as many bricks and Mindstorms parts as shown in the two videos below. I have far less, so I am going to have to be efficient in mimicking them. I have 4 NXTs, 2 RCXs, loads of sensors, and quite a few PF motors and accessories, lots of pneumatic stuff, and lots of 9V stuff. Every good project starts with a good plan.
Here are just a few ways I plan to be efficient;
1. I will build several cars at the same time.
I don’t want to be limited to building only one car at a time. I will have a continuous stream of cars going through the factory. At each cell, another piece will be added. All cells will work simultaneously and when all cells are complete, the process will cycle to the next car.
2. I will use a single stream to construct the vehicle.
On both of these video, you see grippers picking up assemblies and moving them to a different operation. I will be using a single long conveyor belt. Any construction to the vehicle will be done on that conveyor belt. This will force me to standardize, which will make constructing the whole factory easier.
3. All vehicles will be built on a pallet.
As the vehicle construction happens, each car will be placed on its own pallet or sled to move through the factory. This will mean that each cell will locate the pallet exactly the same way following a standardized system.
4. I will use a common pneumatic compressor.
I will build a large air compressor that powers all pneumatic actuators. This will have a standard pressure switch that will be used to turn the compressor on and off. The switch and motor do not use any control ports of the microprocessors.
5. I will excessively use PF motors and the HiTechnic IRLink.
Not all motions will need to have precise locations. I can use a PF motor much like a pneumatic cylinder. I will use a clutch gear and timing in the program to shift the motor from Point A to Point B.
6. I will use a single pneumatic interlocking pusher system.
In the videos, they show several locations where a motor is connected to a spur gear that drives a pusher down to interlock the Lego pieces. I will use a single air system that will push down at all cells at the same time after all parts are laid in place on all cells. This will use one motor to flip the switch.
7. I will use a single system to lock all pallets in place.
This will more than likely be a pneumatic system. As a pallet arrives at a cell, perfect alignment of all pallets at their cells would impossible. I will create a pneumatic system the will lightly push each pallet exactly into place and hold it while the robots work on the car. This will use one motor to flip the switch.
8. I will use a card system to input car details.
In the videos, the user chooses each car color by pushing a series of buttons. I will be creating some sort of card reader that will tell the factory which colors or details to place. This will use one motor and one sensor.
I think I have prepared a plan that will allow me to build a large factory with four to six cells. I have researched some automated car factories and my system mimics their facilities. I think what you will see if this plan works is an orchestra of moving parts. It’s going to take a pretty good conductor, and I hope I am up to the challenge.
Now the plan is in place, time to build. That’s fun part.
Tuesday, October 20, 2009
My Next Project is a Big One!
Well, the DominoBot is torn apart and I am thinking about my next project. I like big things, really big things, and I don’t mind spending months working on a project.
I haven’t posted in a few days because I have been thinking about tackling a project that I have wanted to do for a long, long time. Here are two videos that I have watched dozens of times.
I haven’t posted in a few days because I have been thinking about tackling a project that I have wanted to do for a long, long time. Here are two videos that I have watched dozens of times.
Car Factory
Airplane Factory
These are great; they show lots of creativity and teamwork. It looks to me like an individual or small team constructed a station or cell and then all the cells are brought together to form one large construction.
I am going to give this a try. I think that both can be done with fewer processes and bricks, although I am truly impressed by the massive overbuilding of some components.
I am now trying to construct a vehicle that can be relatively easily mass produced. I am inventorying my wheels and other vehicle components. I don’t really want to purchase a bunch of parts that won’t be used in other projects, so I am trying to stick with what I have on hand.
Over the next few days, I will share some of the engineering choices I have made and why. I have put a lot of thought into this already, and I have some ideas that some of you may be interested in seeing.
By the way, this is a great team project and I am willing to work with others to expand!
These are great; they show lots of creativity and teamwork. It looks to me like an individual or small team constructed a station or cell and then all the cells are brought together to form one large construction.
I am going to give this a try. I think that both can be done with fewer processes and bricks, although I am truly impressed by the massive overbuilding of some components.
I am now trying to construct a vehicle that can be relatively easily mass produced. I am inventorying my wheels and other vehicle components. I don’t really want to purchase a bunch of parts that won’t be used in other projects, so I am trying to stick with what I have on hand.
Over the next few days, I will share some of the engineering choices I have made and why. I have put a lot of thought into this already, and I have some ideas that some of you may be interested in seeing.
By the way, this is a great team project and I am willing to work with others to expand!
Friday, October 16, 2009
The Lego Flexpicker
I realized today that I haven't linked to may current claim to fame, the Lego Flexpicker.
I had a great time with this build. I got tons of links from several big blogs and websites and was even invited to take it to an ABB Robotics show in Michigan. Check out this video and you will see the Lego robot at about 5:50
I had a great time with this build. I got tons of links from several big blogs and websites and was even invited to take it to an ABB Robotics show in Michigan. Check out this video and you will see the Lego robot at about 5:50
Mechanical Ecstasy
I became an Engineer because I have a great fondness for moving things. Lego allows me to quickly throw together ideas and realize thoughts in only a few moments. I easy get transfixed on complicated machines.
Then I found videos from superbird28 on YouTube.com. This person is a mechanical God in my mind. Their creations absolutely mesmerize me. I will link to just one, but I strongly recommend that you check out all of this persons work. It is amazing.
Then I found videos from superbird28 on YouTube.com. This person is a mechanical God in my mind. Their creations absolutely mesmerize me. I will link to just one, but I strongly recommend that you check out all of this persons work. It is amazing.
Wednesday, October 14, 2009
Monday, October 12, 2009
Universal Joint Trivia
Look at the two shaft assemblies below. Identical, right? Not exactly.

Another name for a Lego universal joint is a Cardan joint. One of the drawbacks of a Cardan joint is that even when the input axle rotates at a constant velocity, the output shaft rotates at a variable speed. This can cause vibration in shafts that turn fast and inaccuracy in precision machinery. It’s not typically noticed with Lego because of several reasons. There is not a good way to very precisely measure rotational velocity and angle, there is torsion (twist) in the shafts and the gearing has a lot of backlash or slop, so we don’t see it or even care.
One way to partially overcome this error is to align the hinges on the universal joint as shown on Shaft A (90 degrees apart) and align the input and output shafts so that they are parallel. This is called a Double Cardan Shaft. This arrangement will result in an almost constant velocity in the output shaft.

Another name for a Lego universal joint is a Cardan joint. One of the drawbacks of a Cardan joint is that even when the input axle rotates at a constant velocity, the output shaft rotates at a variable speed. This can cause vibration in shafts that turn fast and inaccuracy in precision machinery. It’s not typically noticed with Lego because of several reasons. There is not a good way to very precisely measure rotational velocity and angle, there is torsion (twist) in the shafts and the gearing has a lot of backlash or slop, so we don’t see it or even care.
One way to partially overcome this error is to align the hinges on the universal joint as shown on Shaft A (90 degrees apart) and align the input and output shafts so that they are parallel. This is called a Double Cardan Shaft. This arrangement will result in an almost constant velocity in the output shaft.

Reference: Wikipedia
Wikipedia’s article on Universal Joints nicely shows the Equation of Motion for a universal joint along with a graph.
Wikipedia’s article on Universal Joints nicely shows the Equation of Motion for a universal joint along with a graph.
Sunday, October 11, 2009
DominoBot!
Here are some pictures and information about the DominoBot.
DominoBot lays dominoes in a pattern to spell out a message. The basic premise is the same as a very very slow dot matix printer.
DominoBot uses one NXT, two servos to drive, one servo to open and close the gate, and eight medium PF motors controlled with the HiTechnic IRLink to push dominoes out of the magazine. The code is written in RobotC and the pattern and array are created in MS Excel.
Inspiration for this project, as I mentioned was Chalkbot. I considered several different mediums to spell out the message including spray paint, bricks, water and finger paint. I chose dominoes because I have two very large sets of dominoes (272 dominoes total), and it would be easy to pick up and reload.


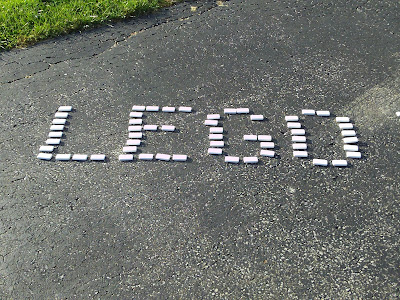


DominoBot lays dominoes in a pattern to spell out a message. The basic premise is the same as a very very slow dot matix printer.
DominoBot uses one NXT, two servos to drive, one servo to open and close the gate, and eight medium PF motors controlled with the HiTechnic IRLink to push dominoes out of the magazine. The code is written in RobotC and the pattern and array are created in MS Excel.
Inspiration for this project, as I mentioned was Chalkbot. I considered several different mediums to spell out the message including spray paint, bricks, water and finger paint. I chose dominoes because I have two very large sets of dominoes (272 dominoes total), and it would be easy to pick up and reload.


The robot weighs over 25 lbs., so I had to carefully build the structure and drive train to be able to support that much weight. It will only work on level, flat surfaces. I once pulled it across the table and broke a gear, so when I move it I have to completely pick it up and place it, even very small distances.
DominoBot needed to be able steer and the wheels have to be extremely robust. I devised two pivoting trucks with four wheels each connected by a differential gear. The differential gear allowed a very wide base for each driving motor while still allowing it to turn.
DominoBot needed to be able steer and the wheels have to be extremely robust. I devised two pivoting trucks with four wheels each connected by a differential gear. The differential gear allowed a very wide base for each driving motor while still allowing it to turn.

The PF motors are used basically the same way a pneumatic cylinder would be used. I cycle the motors forward for 1.5 seconds to push out a domino and reverse for 1.5 seconds to retract the pusher. A clutch gear is used to “bottom out” the pusher on both movements, so a cycle actually takes less than 1.5 seconds.

The gate at the domino exit chute is an afterthought. I found that when the dominoes slide out, they tended to slide four to eight inches and made the message incomprehensible. The gate stops them at the bottom of the chute and releases them at the same time.

I used MS Excel to create the pattern. This worked great because I could size and fill in the cells to see exactly what the pattern would look like. Then I used a couple of Excel formulas and created the actual code that I could copy and paste over to my RobotC program.

Each magazine slot can hold 32 dominoes, which allows for about 10-12 characters to be created. The message programmed right now is “LEGO RULES.” Originally I made the magazine so that it would be filled from the top, then I figured out that it would be much easier to fill from the back.


Subscribe to:
Posts (Atom)


